VEX IQ slime robot demonstrationOpen original
USC · Week 3
VEX IQ Slime Robot
A VEX IQ mechanism that uses gravity-fed cups and a motorized mixer to combine slime ingredients.
WhenSummer 2026
My roleIndependent mechanism design and build
StatusMixing mechanism demonstrated
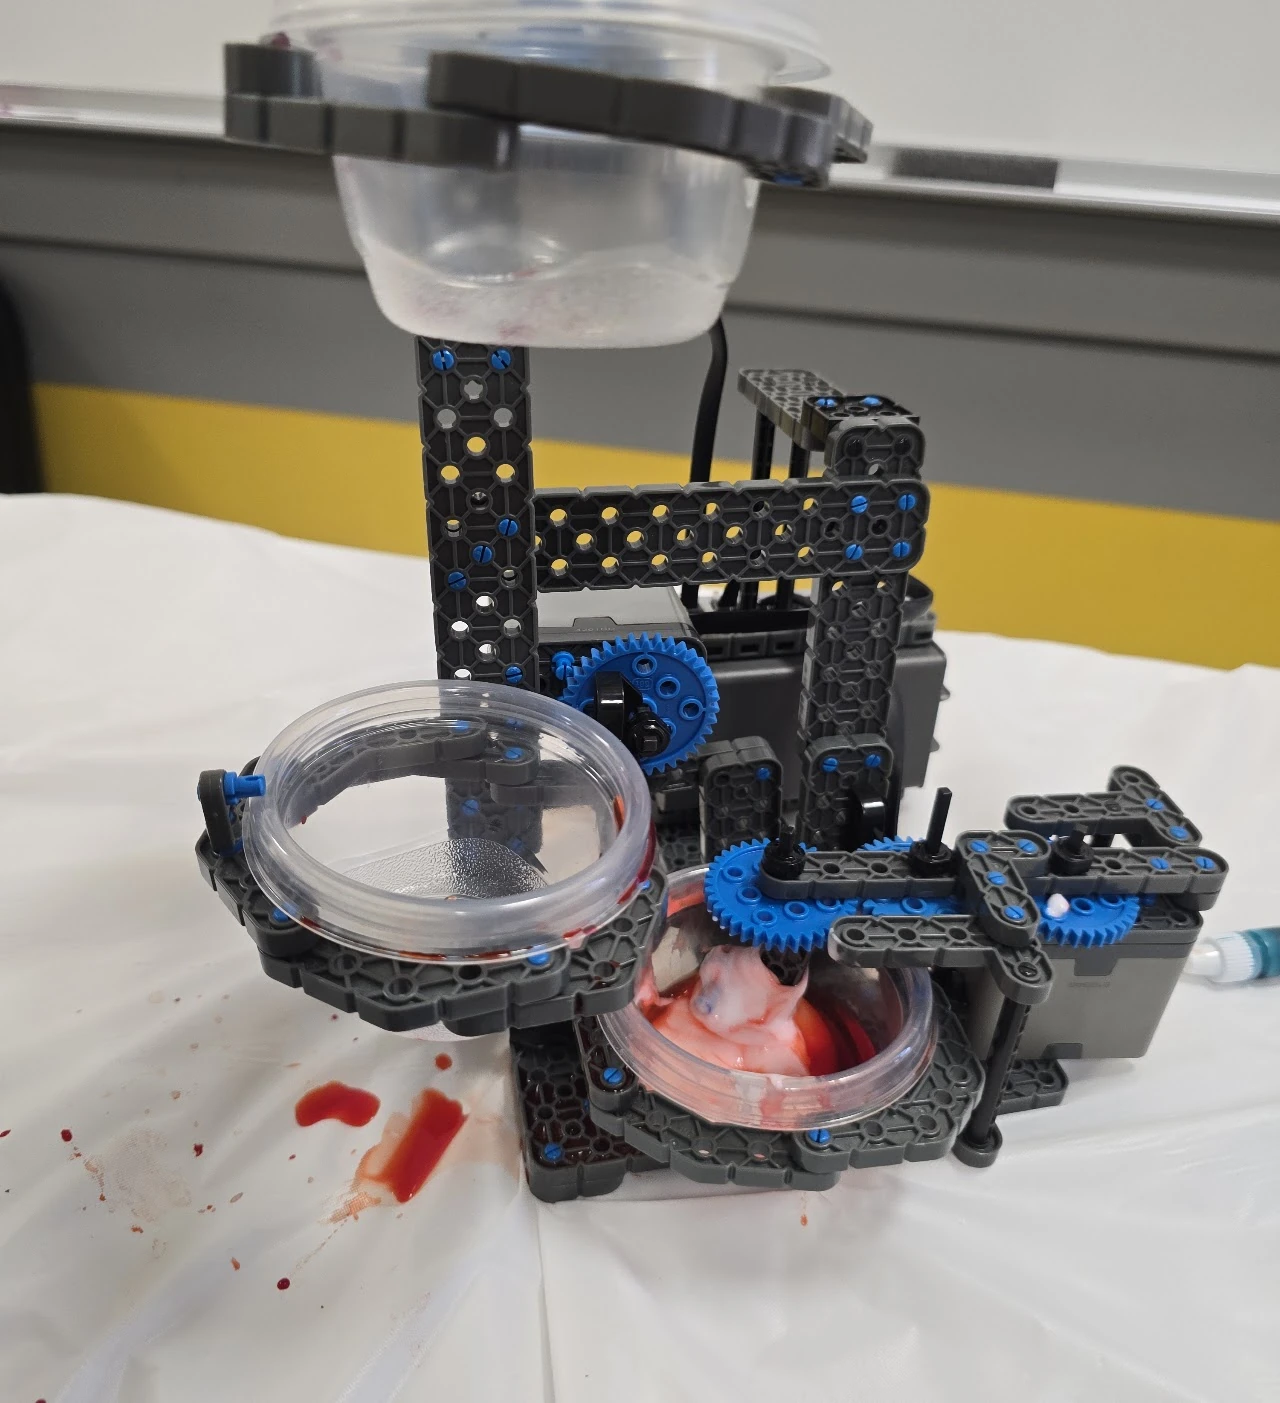
The goal
Dispense and mix slime ingredients with a VEX IQ mechanism.
My work
Independent design and construction of the cup tower and mixer.
Hardest problem
Coordinating gravity-fed ingredient transfer with motorized mixing.
Result so far
The dispensing and mixing mechanism was demonstrated.
The project.
I independently built the VEX IQ slime robot to combine glue and a polymer mixture. The mechanism brought together stacked motors, a tower of cups that intentionally tipped to transfer ingredients by gravity, and an L-shaped dowel mixer.
Dowel mixer
An L-shaped dowel mixed ingredients in the final cup.
Dispense + mix
Intentional cup tipping transferred ingredients by gravity into the mixing arrangement.
Engineering decisions
How it came together.
Use gravity to handle the ingredients
The robot used stacked motors and cups arranged in a tower. Tipping the cups intentionally moved the ingredients through the arrangement by gravity. The dispensing mechanism connected the robot's motion with the path of the materials.
Bring the ingredients and mixer together
The final arrangement used an L-shaped dowel to mix the glue and polymer mixture in a cup. The demonstration shows how the robot's mechanism connects dispensing and mixing in one task.
Mechanism
How the parts work together.
Ingredient handling
Dispense with gravity-fed cups
Use a stacked-motor arrangement and intentionally tipping cups to move ingredients through the mechanism.
Mixing
Mix with an L-shaped dowel
Combine ingredient handling with the dowel mixer in the final cup.
Project photographs
A look at the build.
Explore the hardware, design views, and development stages.
- The slime-making robot connected ingredient handling with a mixing mechanism.
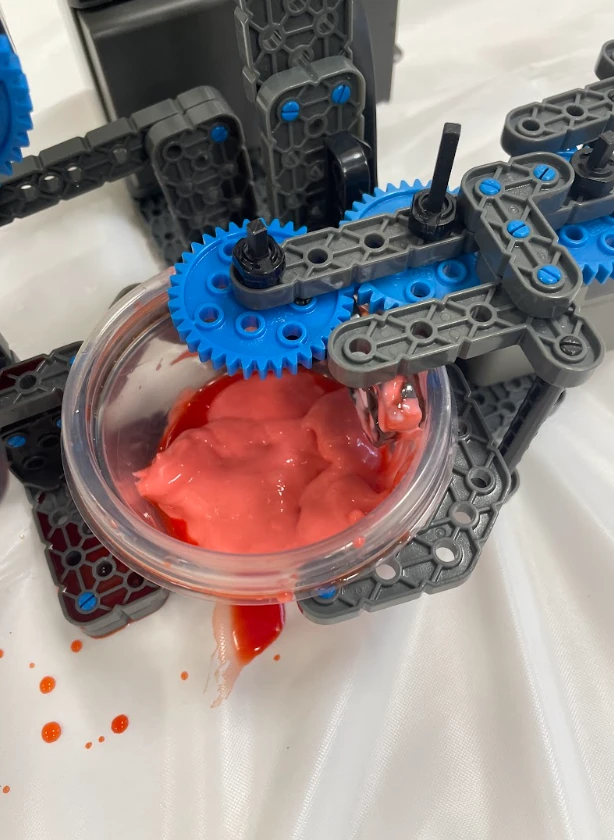
- A closer look at the mixing arrangement.
Demonstrations
See the project
in action.
Original recordings from the USC project documentation.
Play the recordings here, or open them in a separate tab.
Skills developed
VEX IQMechanism designPrototypingRobot integrationIndependent project work